If you’re in the robot game, you know software accessories can make or break your bot’s performance—whether it’s a cobot on a factory line, a delivery bot navigating a campus, or a DIY robot you built in your garage. As a robot accessories supplier, I’ve seen way too many teams mess up setup because they skipped a few key steps, or grabbed random add-ons without checking if they’ll play nice with their hardware. Today, I’m breaking down how to configure these bits like a pro, no jargon overload, and no confusing hoops to jump through. Robot Accessories
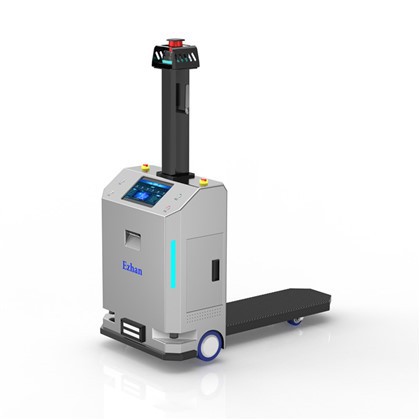
First, let’s get clear on what we’re even talking about here. When I say “robot software-related accessories,” I’m not just talking extra cables or sensors. This covers things like edge computing modules (those little boxes that process data close to the bot instead of sending it to a cloud), software development kits (SDKs) for custom programming, connectivity add-ons (like Wi-Fi 6 adapters or Bluetooth modules that fix dead signal spots), and even vision processing tools that plug into your bot’s main software. The goal here is simple: make sure these accessories sync with your robot’s core software, so everything runs smoothly, no glitches mid-task.
Start with the basics before you even plug anything in. I see so many people jump straight to hardware installation without checking compatibility—don’t be that guy. First, pull up your robot’s official specs (whether it’s a commercial model or a custom build). Let’s say you’ve got a industrial robot arm with a main software stack that runs on ROS (Robot Operating System, that’s the go-to open-source for most bots) Noetic Ninjemys, for example. If you’re eyeing a new LiDAR sensor add-on, check if it has a ROS Noetic-compatible driver. Skip that step, and you’ll spend 3 nights googling why your sensor isn’t publishing data to your bot’s nodes. For commercial bots, most reputable suppliers (cough, like mine) have a compatibility list posted right on our product pages—use that. I always tell customers: if you’re not sure, shoot us a message before buying. We’d rather walk you through it than deal with returns later.
Next, get your environment prepped. This is where a lot of DIYers and small teams cut corners. Let’s break it down by accessory type, because config changes a bit depending on what you’re adding. Let’s start with connectivity accessories—super common, because bad Wi-Fi is the #1 complaint for robots that need remote monitoring. If you’re adding a Wi-Fi 6 adapter to a bot that’s been stuck on old Wi-Fi 4, don’t just plug it in and cross your fingers. First, update your robot’s main software to the latest stable version. Old versions often have buggy firmware that won’t recognize newer adapters. Then, access your bot’s network settings—most bots use a local web dashboard (you can find the IP address in your router’s connected devices list, no fancy tools needed) and disable any old Wi-Fi modules that might interfere. For example, if your bot has a built-in Bluetooth 4.0 and you’re adding a Bluetooth 5.0 module, turning off the old one stops signal overlap. One quick tip here: set a static IP for your bot and the new accessory, not DHCP. That way, you don’t have to reconfigure the connection every time your router restarts. Saved me so many late nights debugging delivery bots that kept losing signal because their IP changed mid-route.
Now, SDKs and custom programming accessories—these are for when you want your bot to do something specific, like sort packages by weight or follow a custom safety path. Let’s say you bought our custom SDK for cobot force torque sensors. First, don’t just download the SDK and run the installer blindly. Most SDKs depend on specific libraries—like Python 3.8 or OpenCV 4.5, depending on the model. If your robot runs Python 3.10, the old libraries won’t work, and you’ll get error messages that make zero sense. Use a virtual environment! That’s a tool that keeps your SDK’s libraries separate from your main robot software, so no conflicts. I always include a quick virtual env setup guide with every SDK we ship, but if you skip it? You’ll be fighting “module not found” errors for hours. Another thing: test the SDK with a basic script first, not your full robot. Like, if the SDK is for a gripper accessory, write a small script that just makes the gripper open and close, then move up to integrating it with your bot’s navigation. That way, if something breaks, you know it’s the accessory config, not your whole system.
Edge computing modules are another big one these days—everyone wants to process data on the bot to cut lag. Configuring these is a little different because they’re mini-computers, so you have to sync their software with your bot’s. First, make sure the module’s OS (like Ubuntu Server, super common for edge gear) matches your robot’s core OS. If your robot runs ROS Noetic on Ubuntu 20.04, don’t pair it with an edge module running Ubuntu 22.04—different versions have different library dependencies, and you’ll get cross-compiling errors. Once you’ve got the OS match, set up remote access between the edge module and your bot. SSH is still the easiest way for this—most edge modules come with a default SSH key, so you just add your bot’s SSH public key to the module’s authorized keys file. That way, you can run commands on the module from your bot’s main controller, no need to plug a monitor into the edge box every time. Pro tip: assign the edge module to a separate network segment if your bot is on a factory network. That keeps the edge data processing secure, and if the module crashes, it won’t take down your whole network.
Vision accessories, like cameras for object detection, need extra config because they handle a lot of data. Let’s say you’re adding a 4K fisheye camera to your bot for warehouse inventory checks. First, calibrate the camera before you plug it into your main software. Most vision accessories come with a calibration pattern (a chessboard, usually) and a tool to adjust for lens distortion. Skip calibration, and your object detection will be off by inches—big deal when a bot is picking up small parts. Once calibrated, make sure your vision software (like TensorFlow Lite or PyTorch) is optimized for the camera’s resolution. If your camera outputs 4K frames, but your bot’s main controller can only process 1080p, you’ll get lag. Lower the camera’s frame rate or resolution in the camera’s settings until it matches what your bot can handle. We include a calibration tool with every camera accessory we sell, and a quick video walkthrough—no need for a PhD in computer vision to use it.
Wait, let’s talk about post-config checks—this is non-negotiable. You could follow every step perfectly, but if you don’t test the accessory in a real scenario, you might miss something. Here’s a routine I give all our customers: 1) Run a diagnostic test specific to the accessory. For a sensor, check if it’s publishing data at the right rate. For a gripper, test it with a dummy object similar to what it’ll handle. 2) Do a load test. If it’s a factory robot, run it for 4 hours straight—no accessories crash after 10 minutes, so run it long enough to catch memory leaks or signal drops. 3) Check for software conflicts. Use your robot’s main software’s process monitor to make sure the accessory’s process isn’t using 90% of the CPU (that’ll slow down your bot). If it is, adjust the process priority—most systems let you set that in the accessory’s config file.
I’ve gotta be real here: sometimes things go wrong even when you do everything right. Maybe a firmware update from your robot’s manufacturer broke compatibility with our sensor accessory. Or maybe a router glitch messed up your connectivity. That’s where having a good supplier matters—we don’t just sell you a box and disappear. If you run into issues, shoot us a note with your robot’s model, the accessory part number, and a screenshot of the error message. We’ll walk you through troubleshooting, and if it’s a config issue we missed, we update our guides the same day. No hoops, no long wait times—just actual people who work with these accessories every day.
Let’s wrap this up with a quick recap to make sure you don’t forget the key steps: 1) Check compatibility before buying, 2) Prep your environment (update software, create virtual envs, static IPs), 3) Configure based on accessory type (connectivity, SDK, edge, vision), 4) Calibrate and test, 5) Follow up if you need help.
If you’re gearing up to add software accessories to your robot—whether you’re a small business outfitting delivery bots for your campus, a factory upgrading cobots, or a hobbyist building a new DIY robot—don’t stress the config. We’ve got all the tools, guides, and support to make it painless. If you’re ready to chat through what you need, hit us up to connect and talk about your robot setup. We can help pick the right accessories, walk through config steps, and make sure everything works like it’s supposed to.

One last thing: always keep docs. Jot down what accessory you added, the version of the driver/SDK, config settings, and any issues you ran into. That’ll save you hours when you update your robot’s software next year. Trust me, I’ve seen way too many teams lose weeks because they didn’t write down how they set up their accessory.
Hybrid Robot References
- Robotics Software Association. (2023). “Compatibility Guidelines for Robot Software Accessories.” RSA Technical Brief.
- Open Source Robotics Foundation. (2022). ROS Noetic Ninjemys Configuration and Setup Guide.
- Industrial Robot Association. (2023). Edge Computing Integration for Cobots: Best Practices.
- Computer Vision Foundation. (2022). Calibration Standards for Mobile Robot Vision Accessories.
- Wireless Robotics Network. (2023). Connectivity Config for Autonomous Robots: Minimizing Signal Lag.
Shenzhen Ezhan Technology Co., Ltd.
We’re known as one of the most reliable robot accessories manufacturers and suppliers in China. With abundant experience, we warmly welcome you to buy bulk customized robot accessories from our factory. If you have any enquiry about cooperation, please feel free to email us.
Address: Room 1808, 1809, 1810, Building 2, Aipark, Baolong 4th Road, Longgang District, Shenzhen City
E-mail: sales01@ezhankeji.com
WebSite: https://www.ezhanrobot.com/
